
Autonomy Library·Reference
What is robot obstacle avoidance?
Robot obstacle avoidance is a robot’s ability to detect what is in its path and steer around it before contact. It is a component of autonomy, not a synonym for it: what a robot senses, and what it then decides to do, are separate problems, and each sensor type fails differently.
Counts are live·reviewed July 5, 2026
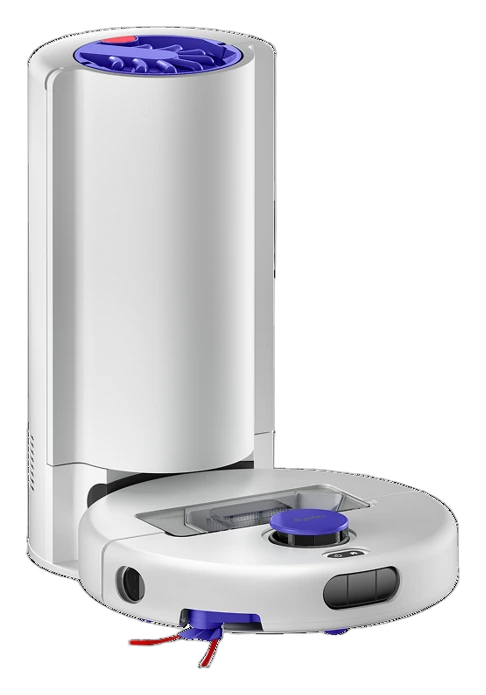
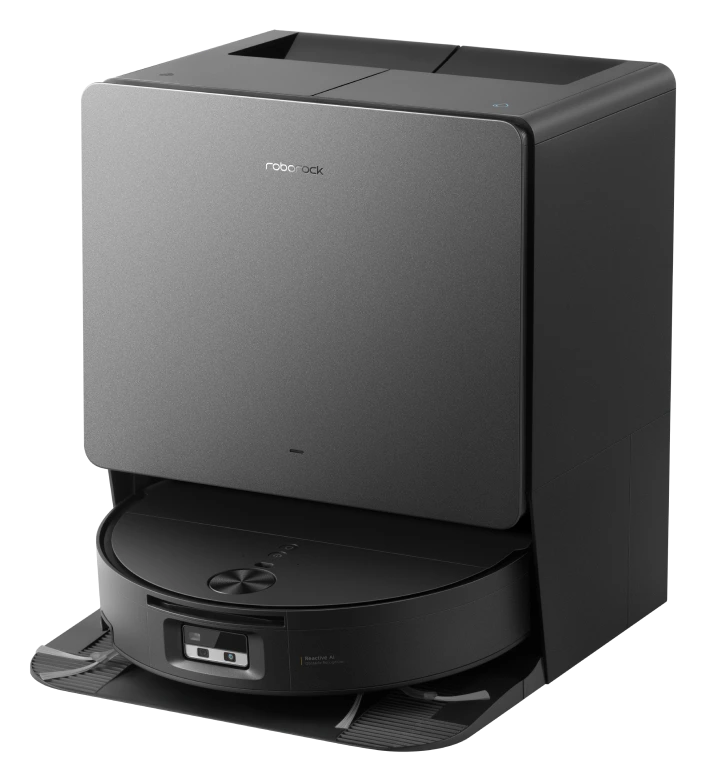
The same hallway, three ways of seeing it
- 1
The thresholdThe smallest height the sensor resolves. Everything below this line is driven over rather than avoided, whatever the obstacle is.
- 2
AvoidedTall enough to cross the threshold, so it registers before contact and the route bends around it.
- 3
Driven intoA sock, a charging cable and pet waste all lie below the sensor floor, so the route runs straight over them.
Detection is not behavior
Obstacle avoidance is marketed as a sensor spec and experienced as a behavior. Between the two sits a decision policy: how wide to steer, when to slow, what to do about an object the robot is unsure of.
That policy is a tradeoff the spec sheet never states. Avoid too cautiously and the robot skips cleanable floor around every shadow. Avoid too confidently and it eats a phone cable. What the phrase on the box actually commits to is examined in what “avoids obstacles” actually claims.
The sensing stack
Four detection approaches, each with characteristic strengths and blind spots. Many robots combine two or more.
| Camera with on-board recognition | Identifies object classes, which enables object-specific behavior such as wide margins around pet waste. Depends on lighting and training data; novel objects and dim rooms degrade it. |
|---|---|
| LiDAR | Precise ranging for mapping and wall-following, independent of lighting. Mounted high, so it can miss low, small objects exactly where clutter lives. Struggles with mirrors and glass. |
| Structured light and depth sensors | Project patterns to read close-range 3D shape, good for small-object detection ahead of the robot. Range is short and direct sunlight interferes. |
| Infrared and bump sensors | The baseline layer: cliff detection and contact response. On budget robots this is the entire system, which means avoidance happens by touching things gently. |
The hard objects
Owner reports across the database name a consistent set of adversaries: cords and cables, socks and clothing, rug tassels, pet waste, high thresholds, dark floors that trigger cliff sensors, chair bases, and mirrors. These recur because they are thin, low, deformable, reflective, or ambiguous, the exact properties each sensor type handles worst.
The failure geometry is covered in getting stuck: thresholds, dark floors, and strand events.
Avoidance and the Autonomy Ladder
Obstacle avoidance is one of the clearest dividers between Level III and Level IV on the autonomy levels scale. A Level III robot avoids common obstacles in a familiar space and strands on the unusual ones. Level IV requires handling the unfamiliar without rescue. For most indoor robots, the distance between those sentences is the state of the art.
Questions
What is the difference between obstacle avoidance and object recognition?
Recognition identifies what an object is; avoidance is what the robot does about it. A robot can avoid an object it cannot identify, and recognizing an object does not guarantee sensible behavior around it. The marketing often presents recognition counts as if they were avoidance performance.
Does obstacle avoidance work in the dark?
It depends on the sensors. Camera-based recognition degrades in dim light unless the robot carries its own illumination. LiDAR works in darkness but sits too high to see small floor objects. Robots that combine both keep partial capability at night.
Why does my robot still hit furniture?
Light contact is often intended behavior: many robots use gentle touch to establish edges, especially with bump-sensor navigation. Repeated hard strikes suggest sensor occlusion, a dark or reflective surface confusing detection, or clutter below the sensor line.
Is camera or LiDAR obstacle avoidance better?
They fail differently. Cameras classify objects but need light and training; LiDAR ranges precisely but misses low clutter and mirrors. Robots that fuse camera, LiDAR, and close-range depth sensing cover more failure modes than any single sensor.
Does good obstacle avoidance mean a higher autonomy level?
It contributes. Avoiding ordinary obstacles before contact is one of the three Level IV requirements, alongside coping without the space being cleared and freeing itself when stuck. Each has to be documented as behavior, not inferred from a sensor list, and an independent report outranks the maker where the two disagree.
Robot Vacuum Autonomy·Robot Autonomy Levels·Robot Autonomy·Robot Firmware Update·Full library
Browse classified robot vacuums →·Analysis: what “avoids obstacles” claims →
Cite this page
Robovations. “What Is Robot Obstacle Avoidance?” Robovations Autonomy Library. Last reviewed July 5, 2026. https://robovations.com/robot-obstacle-avoidance/