
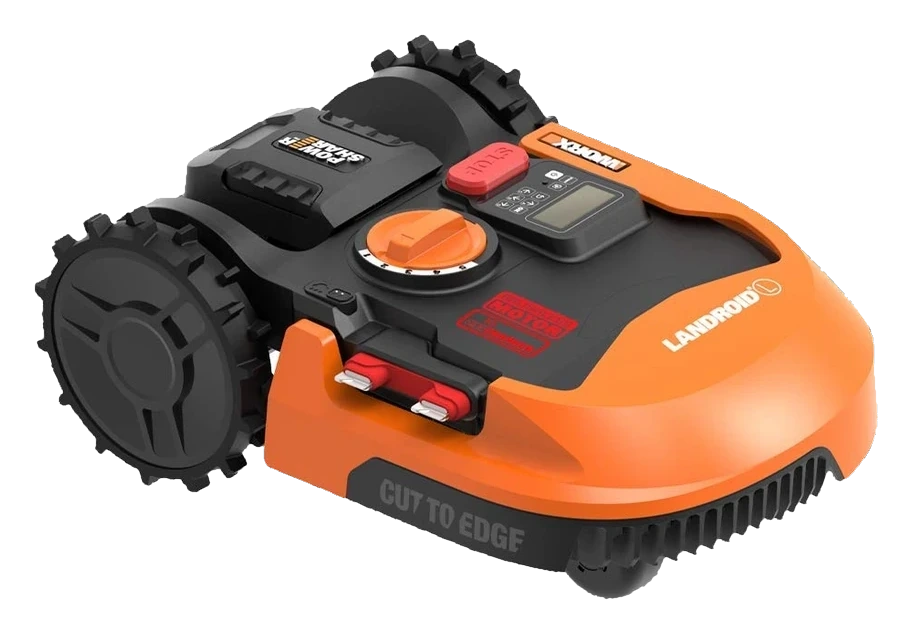
- Autonomy
- IIAssisted
- Score
- 66/100Capable
- Readiness
- Ready Now
- Price
- $999list
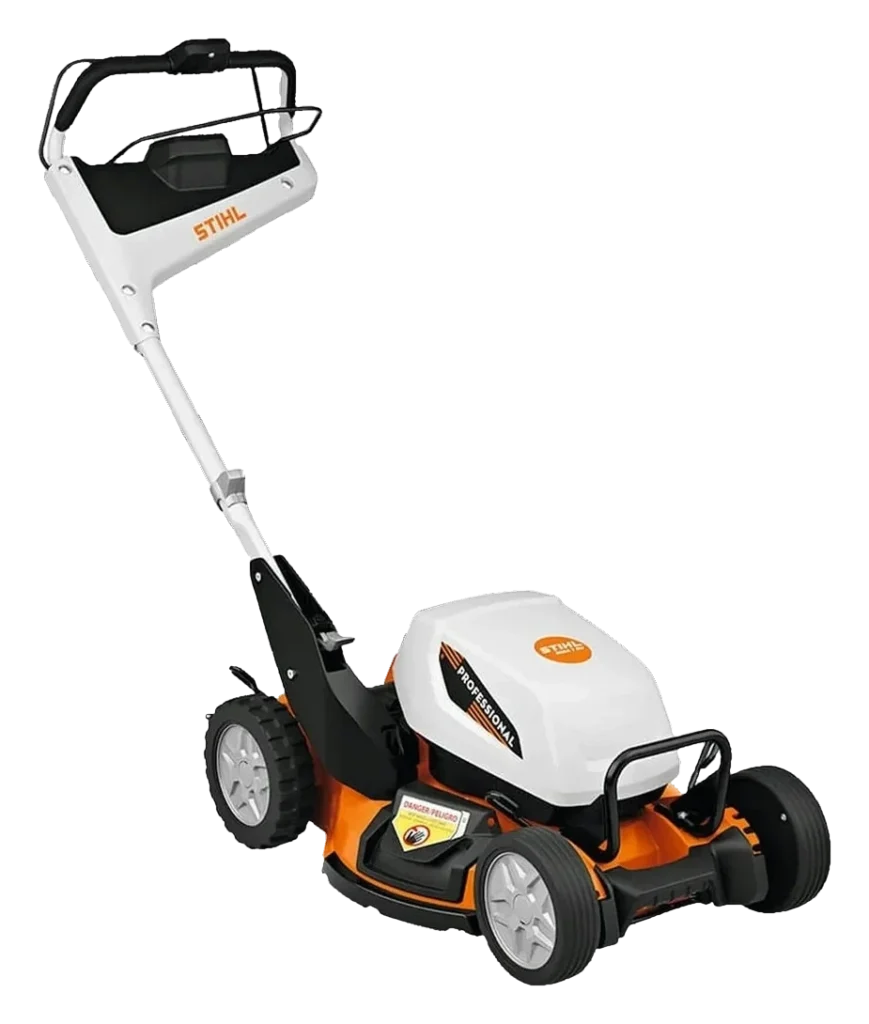
Stihl
Up to three
All robot lawn mowers. Every figure below is placed against the whole class, so a gap can be read against how much the class itself varies.
The conditions each robot was assessed against, side by side. Rows marked in gold are where these machines genuinely differ.
| Condition | Landroid L 20V WR155 | Stihl iMow 7 |
|---|---|---|
| Yard size | ||
| Under ¼ acre | GoodCovers sub-quarter-acre easily in one charge without repositioning. | GoodOversized for small yards; covers efficiently but underutilizes runtime capacity. |
| ¼ – ½ acre | GoodHalf-acre properties fit within one to two charge cycles; dock repositioning handles multiple passes. | GoodIdeal deployment zone; systematic pattern and 420-min runtime cover this range in single session. |
| Over ½ acre | DependsOver-half-acre requires three or more charge cycles; coverage becomes probabilistic without systematic route planning. | DependsRated 5,000 sq m (~1.24 acres), the top of the iMOW range; larger yards need a second machine rather than a larger one. |
| Terrain | ||
| Mostly flat | GoodWire guidance and flat terrain allow reliable coverage and docking between cycles. | GoodFlat terrain is the baseline; iMow 7 excels without slope challenges limiting traction. |
| Gentle slopesthey differ | DependsSlopes up to 15% are manageable but cause uneven cutting and slower progress; traction loss documented on wet grass. | GoodRated to 45% gradient; moderate slopes are well within operating specifications per owner reports. |
| Steep / hillythey differ | PoorWire-only guidance cannot sense or navigate slopes above 15%; traction loss and coverage failure are documented. | DependsNear the 45% limit on wet grass, traction degrades; dry conditions perform better than wet. |
| Grass type | ||
| Typical lawn grass | GoodStandard grass species cut reliably with scheduled blade replacement. | GoodStandard turf and lawn grasses are the design baseline; systematic mowing pattern optimized for normal growth. |
| Mixed / tall growth | DependsTall grass clogs blades faster, requiring more frequent replacement and cleaning. | DependsTall or overgrown grass may require multiple passes; blade wear accelerates with dense growth. |
| Thick (Bermuda / Zoysia) | DependsThick Bermuda or densely turfed grass causes motor strain; weekly maintenance and frequent blade changes needed. | DependsThick Bermuda or St. Augustine grass reduces cut speed; may require reduced cutting-height settings or longer run-time allocation. |
| Boundary setup | ||
| Wireless required | PoorThe WR155 is wire-dependent; virtual or wireless boundaries are not supported. | PooriMow 7 requires physical perimeter wire; no wireless virtual-boundary option available. |
| Wire required | GoodDesigned for buried wire; installation one-time but required. | GoodPhysical perimeter wire is the required boundary system; installation is a one-time setup cost. |
| No preference | GoodAny property with perimeter wire infrastructure supports WR155 navigation. | GoodUses perimeter wire. Fits readers with no boundary preference; wire is required. |
A robot being poor for a condition is a fact about fit, not a fault. “Depends” means the record names a limit worth reading, not that the answer is unknown.
Nine inputs across three pillars, each weighted as shown and each scored so more is better. A robot can lead on one and trail on another, which is the point of showing them apart.
A number only means something next to the spread it sits in. Each track is the real range across every classified robot in the class, with the median marked.
Not compared, because fewer than two of these robots carry a published figure: Price.
Written on each record, and the only thing here every robot on the site carries.
What each design gives up to be good at what it is good at.
Connecting the mower to Worx’s cloud is what supplies remote scheduling and fault alerts; running it unconnected is possible because the onboard LCD and dial handle scheduling on their own, but a stoppage out in the yard is then only found by walking out to it.
The boundary wire is the only thing defining the property edge, so it needs inspection and repair after rain, aeration or seasonal ground movement. Nothing about the machine’s path planning reduces that.
Wire installation is a permanent setup: any lawn reconfiguration requires physical wire relocation, unlike virtual-boundary or GPS-based alternatives.
Systematic mowing pattern reduces pass overlap compared to random-path alternatives, but the iMow 7 slows for what its ultrasonic sensors register and bumps the rest; it does not plan a route around a newly placed obstacle.
Stated by the record itself. A robot being wrong for a household is a fact about fit, not a fault.
The upkeep ownership hands back to you, whatever the autonomy level says.
Classifications rest on different depths of evidence. A pre-release assessment and a verified one are not the same kind of claim.
| Robot | Evidence status | Sources reviewed | Last assessed |
|---|---|---|---|
| Worx Landroid L 20V WR155 | Provisional | 4 | Aug 2026 |
| Stihl iMow 7 | Pending | 5 | Aug 2026 |
Evidence status counts the sources behind a classification, not their kind. A high count can be maker documentation and price coverage, so read it as how much was reviewed rather than as independent testing. How we weigh evidence.
 The full recordWorx Landroid L 20V WR155Specifications, evidence, the Fit Check in full, and every tracked change.
 The full recordStihl iMow 7Specifications, evidence, the Fit Check in full, and every tracked change.
Robovations classifies robots; it does not rank them. Nothing on this page is a recommendation, and no manufacturer influences a classification or its placement here.
Comparing across classes is allowed — the page will switch to per-class positioning and tell you it has.