
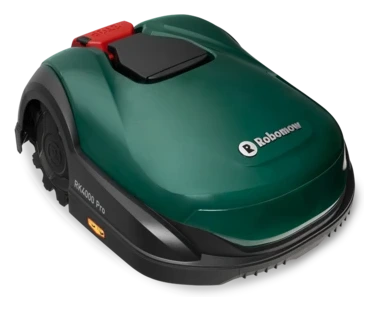
Robomow
Robomow RK4000
- Autonomy
- IIAssisted
- Score
- 69/100Capable
- Readiness
- Ready Now
- Price
- $1,999list
Robomow
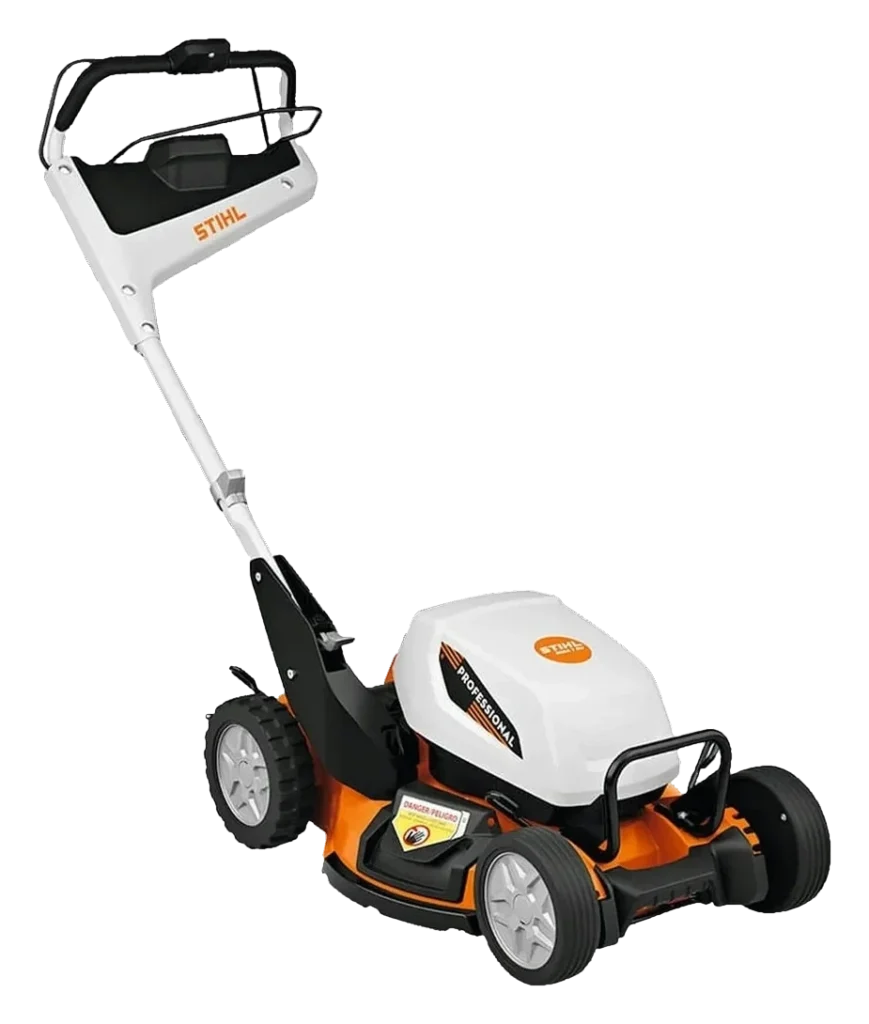
Stihl
Up to three
All robot lawn mowers. Every figure below is placed against the whole class, so a gap can be read against how much the class itself varies.
The conditions each robot was assessed against, side by side. Rows marked in gold are where these machines genuinely differ.
| Condition | Robomow RK4000 | Stihl iMow 7 |
|---|---|---|
| Yard size | ||
| Under ¼ acre | GoodRuntime stretches thin on a 1/4-acre lot in a single cycle; works fine with split sessions or a slightly larger model. | GoodOversized for small yards; covers efficiently but underutilizes runtime capacity. |
| ¼ – ½ acre | Good3,000-7,000 sqft is the optimal range; single battery charge covers most yards in this band. | GoodIdeal deployment zone; systematic pattern and 420-min runtime cover this range in single session. |
| Over ½ acre | DependsYards over 7,000 sqft may require multiple charge cycles; runtime tops out at 2 hours per battery. | DependsRated 5,000 sq m (~1.24 acres), the top of the iMOW range; larger yards need a second machine rather than a larger one. |
| Terrain | ||
| Mostly flat | GoodRandom-pattern coverage completes reliably on flat ground; the pendulum-suspended deck needs no incline compensation here. | GoodFlat terrain is the baseline; iMow 7 excels without slope challenges limiting traction. |
| Gentle slopes | GoodRobomow rates the RK4000 to a 45% gradient (about 24 degrees); gentle slopes sit well inside that rating. | GoodRated to 45% gradient; moderate slopes are well within operating specifications per owner reports. |
| Steep / hilly | DependsRated to 45% gradient (about 24 degrees) with passive slip-based traction; steeper banks exceed the rating and wet grass reduces grip. | DependsNear the 45% limit on wet grass, traction degrades; dry conditions perform better than wet. |
| Grass type | ||
| Typical lawn grass | GoodRandom-pattern coverage completes over typical lawn grass with no reported cutting-quality issues on standard turf. | GoodStandard turf and lawn grasses are the design baseline; systematic mowing pattern optimized for normal growth. |
| Mixed / tall growth | DependsNo published cutting-height range; mixed or tall growth performance is not documented for the offset-blade deck. | DependsTall or overgrown grass may require multiple passes; blade wear accelerates with dense growth. |
| Thick (Bermuda / Zoysia) | DependsBlade torque and cutting-height range for dense Bermuda or Zoysia are unpublished; performance on thick turf is unconfirmed. | DependsThick Bermuda or St. Augustine grass reduces cut speed; may require reduced cutting-height settings or longer run-time allocation. |
| Boundary setup | ||
| Wireless required | PoorThe RK4000 requires a buried boundary wire; there is no wire-free or RTK navigation mode available. | PooriMow 7 requires physical perimeter wire; no wireless virtual-boundary option available. |
| Wire required | GoodThis model is wire-guided by design; boundary wire installation is the standard, documented setup path. | GoodPhysical perimeter wire is the required boundary system; installation is a one-time setup cost. |
| No preference | GoodAny boundary preference is satisfied here since the RK4000 ships as a wire-guided mower only. | GoodUses perimeter wire. Fits readers with no boundary preference; wire is required. |
A robot being poor for a condition is a fact about fit, not a fault. “Depends” means the record names a limit worth reading, not that the answer is unknown.
Nine inputs across three pillars, each weighted as shown and each scored so more is better. A robot can lead on one and trail on another, which is the point of showing them apart.
A number only means something next to the spread it sits in. Each track is the real range across every classified robot in the class, with the median marked.
Not compared, because fewer than two of these robots carry a published figure: Price.
Written on each record, and the only thing here every robot on the site carries.
What each design gives up to be good at what it is good at.
Boundary-wire guidance eliminates line-of-sight operator control, but requires significant one-time and seasonal infrastructure maintenance that systematic-mapping systems avoid.
Random coverage patterns reduce planning complexity, but result in less uniform grass height and longer mowing cycles than systematic mapping approaches.
Wire installation is a permanent setup: any lawn reconfiguration requires physical wire relocation, unlike virtual-boundary or GPS-based alternatives.
Systematic mowing pattern reduces pass overlap compared to random-path alternatives, but the iMow 7 slows for what its ultrasonic sensors register and bumps the rest; it does not plan a route around a newly placed obstacle.
Stated by the record itself. A robot being wrong for a household is a fact about fit, not a fault.
The upkeep ownership hands back to you, whatever the autonomy level says.
Classifications rest on different depths of evidence. A pre-release assessment and a verified one are not the same kind of claim.
| Robot | Evidence status | Sources reviewed | Last assessed |
|---|---|---|---|
| Robomow RK4000 | Pending | 4 | Sep 2026 |
| Stihl iMow 7 | Pending | 5 | Aug 2026 |
Evidence status counts the sources behind a classification, not their kind. A high count can be maker documentation and price coverage, so read it as how much was reviewed rather than as independent testing. How we weigh evidence.
 The full recordRobomow RK4000Specifications, evidence, the Fit Check in full, and every tracked change.
 The full recordStihl iMow 7Specifications, evidence, the Fit Check in full, and every tracked change.
Robovations classifies robots; it does not rank them. Nothing on this page is a recommendation, and no manufacturer influences a classification or its placement here.
Comparing across classes is allowed — the page will switch to per-class positioning and tell you it has.