
RoboParty RP1
A fully open-source bipedal humanoid, built on RoboParty's own Romomo actuators, that recovered its balance live on stage when IROS 2026 visitors pushed and kicked it.
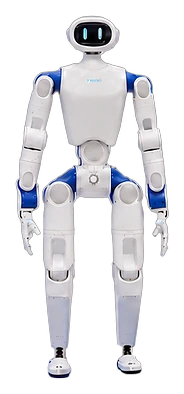
Will the RoboParty RP1 fit your scenario?
Describe your scenario using the controls. Each choice reads the spec sheet for you, flagging where the RoboParty RP1 is built for your space and where it isn’t.
A classification of fit for the conditions you set, not a recommendation. Verdicts describe engineering design intent, not test results.
The full spec sheet.
Manufacturer-published figures, measured against every humanoid robot we track.
What people actually ask.
OperationCan an individual buy a RoboParty RP1 today?
OperationWhat did RP1 actually demonstrate at IROS 2026?
OperationHow is RP1 different from RoboParty's earlier RPO project?
OperationWhat is the peak joint torque RoboParty has published for RP1?
OperationIs RP1's software stack actually open source yet?
 II
Zeroth Bridge
 II
Sanctuary AI Phoenix Gen 8
 II
Unitree H2 Plus
 II
Leju Kuavo 5
Reference the RoboParty RP1 classification.
Embed the Autonomy Ladder™ mark or copy the citation. The mark is served from this record, so a reassessment updates it on your page automatically.
Get the embed code and citation
Scale proportionally only, up to 2× (536px wide)(224px wide). No recolouring, cropping, rotating, or re-typesetting.
Robovations. "RoboParty RP1: Autonomy Level II (Assisted Autonomy)." Autonomy Ladder™, assessed October 2026. https://robovations.com/robots/roboparty-rp1/
- Link it. The mark must point at this record. An unlinked mark is not authorised.
- Hot-link it. Never download, self-host, or re-upload the image. A saved copy stops updating, and a mark that has stopped updating is a claim we no longer stand behind.
- A classification, not an endorsement. It may not appear beside language implying Robovations recommends, rates, or approves the product.