
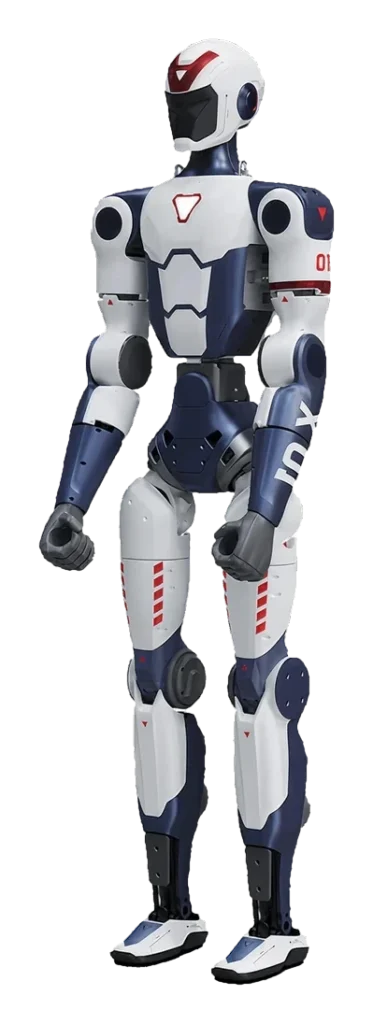
Unitree
Unitree R1
- Autonomy
- IIAssisted
- Pre-release
- 70/100Plausible
- Readiness
- Not assessed
- Price
- $5,900list
Unitree
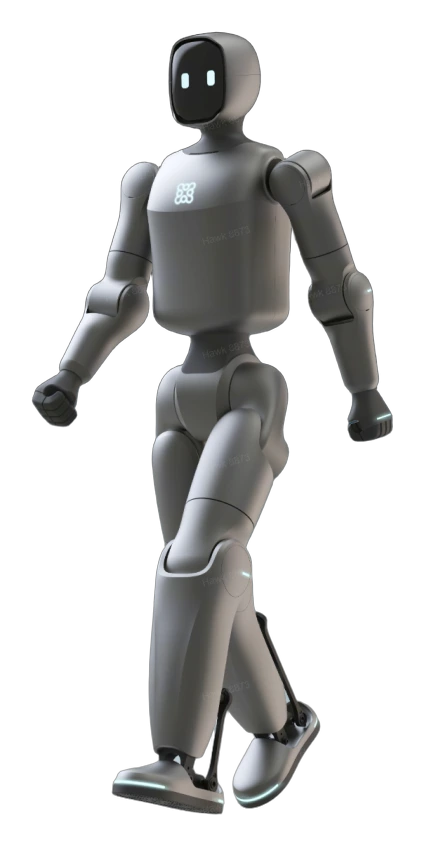
Zeroth
Up to three
All humanoid robots. Every figure below is placed against the whole class, so a gap can be read against how much the class itself varies.
The conditions each robot was assessed against, side by side. Rows marked in gold are where these machines genuinely differ.
| Condition | Unitree R1 | Zeroth Bridge |
|---|---|---|
| Where it operates | ||
| Home / residential | DependsFlat floor requirement; stairs, thresholds above 5cm, and carpeting can cause locomotion failure. | DependsBuilt as a developer and research platform, not a home appliance; it performs no documented household task. |
| Office / retailthey differ | GoodOpen floor layouts and controlled environments align with design assumptions and deployment use cases. | DependsSold to universities, research teams and developers for skill building, not packaged for a commercial service role. |
| Warehouse / factorythey differ | DependsRequires power access and flat work surfaces; not rated for extreme temperatures or continuous 24/7 operation. | PoorNo ingress rating or industrial payload spec; a 2 kg two-finger grip suits bench work, not factory duty. |
| Primary tasks | ||
| Household chores | PoorNo end-effectors or arms; cannot grasp, carry, or manipulate objects. Locomotion-only design. | PoorBuilt-in skills are walking, squatting, dancing and backflips; no household or workplace chore is documented. |
| Social / care | DependsCan perform choreographed demonstrations and tours, but cannot interact autonomously; requires scripted control. | DependsCarries a microphone array and touch sensing but no documented conversational or companion software ships with it. |
| Specialized job | GoodResearch, dynamics modeling, and gait optimization tasks align with open firmware and modular architecture. | GoodA published joint map, open SDK and VR teleoperation suit specialized locomotion and manipulation research. |
| Supervision needs | ||
| Fully autonomousthey differ | DependsScripted missions work autonomously in flat spaces; unexpected obstacles or novel terrain require human intervention. | PoorNo autonomous task completion is documented; it cannot be left to run a job unattended. |
| With oversightthey differ | GoodDesigned for researcher oversight; teleoperation fallback and real-time parameter tuning are standard. | DependsFall recovery is undocumented for a 13 kg biped doing backflips; keep a person watching and the area clear. |
| Teleoperated | GoodROS command interface and teleoperation support tight human control loops for test and validation work. | GoodTele_Bridge provides real-time whole-body VR teleoperation, the robot's intended hands-on operating mode. |
| Timeline | ||
| Ready todaythey differ | DependsShips to institutions now but requires ROS expertise; not turn-key for users without software integration skills. | PoorAnnounced September 2026 as a first-batch pre-order with no delivery date; no delivered unit is documented. |
| Near-term (1–2 yrs)they differ | GoodStable firmware across two major releases; manufacturer ecosystem growing with academic community adoption. | DependsBeta SDK and simulation access opened September 2026, but hardware ship timing is still unstated. |
| Research phase | GoodOpen architecture and modular design positioned explicitly for research validation and algorithm development. | GoodPositioned as an open research and development biped, which is the maturity stage it genuinely occupies. |
A robot being poor for a condition is a fact about fit, not a fault. “Depends” means the record names a limit worth reading, not that the answer is unknown.
None of these has shipped, so they are assessed on track record, engineering plausibility and how the demonstrations match the claims.
Never averaged into it. These describe how much the maker has disclosed, not what the machine does.
| Unitree R1 | Zeroth Bridge | |
|---|---|---|
| ReadinessShip-date specificity, pricing transparency, distribution and regulatory status. Published beside the number; never averaged in. | 100/100 | 60/100 |
| DisclosureHow much of the product is disclosed. Higher means fewer fundamental unknowns remain. Published beside the number; never averaged in. | 85/100 | 45/100 |
A number only means something next to the spread it sits in. Each track is the real range across every classified robot in the class, with the median marked.
Not compared, because fewer than two of these robots carry a published figure: Runtime, Charge time, Noise.
Written on each record, and the only thing here every robot on the site carries.
What each design gives up to be good at what it is good at.
Swappable packs instead of long endurance: about an hour of runtime keeps the robot light and the price low, and shifts continuous operation onto holding and rotating spares.
Lower price expands research access but correlates with reduced actuator redundancy and smaller support community than H1/G1.
Open ROS interface supports customization but demands integration effort; closed competitors offer more plug-and-play operation.
$3,999 buys a biped with a published joint map and no published runtime.
Because control is replayed motion or live teleoperation, every new behavior is something a developer has to build.
Two weights on one page: about 10 kg in the header, about 13 kg in the spec table.
Stated by the record itself. A robot being wrong for a household is a fact about fit, not a fault.
The upkeep ownership hands back to you, whatever the autonomy level says.
Classifications rest on different depths of evidence. A pre-release assessment and a verified one are not the same kind of claim.
| Robot | Evidence status | Sources reviewed | Last assessed |
|---|---|---|---|
| Unitree R1 | Not Consumer-Ready | 10 | Aug 2026 |
| Zeroth Bridge | Pre-Release | 6 | Oct 2026 |
Evidence status counts the sources behind a classification, not their kind. A high count can be maker documentation and price coverage, so read it as how much was reviewed rather than as independent testing. How we weigh evidence.
 The full recordUnitree R1Specifications, evidence, the Fit Check in full, and every tracked change.
 The full recordZeroth BridgeSpecifications, evidence, the Fit Check in full, and every tracked change.
Robovations classifies robots; it does not rank them. Nothing on this page is a recommendation, and no manufacturer influences a classification or its placement here.
Comparing across classes is allowed — the page will switch to per-class positioning and tell you it has.