

SwitchBot
SwitchBot Onero H1
- Autonomy
- IIAssisted
- Pre-release
- 54/100Plausible
- Readiness
- Not assessed
- Price
- $9,999list
SwitchBot
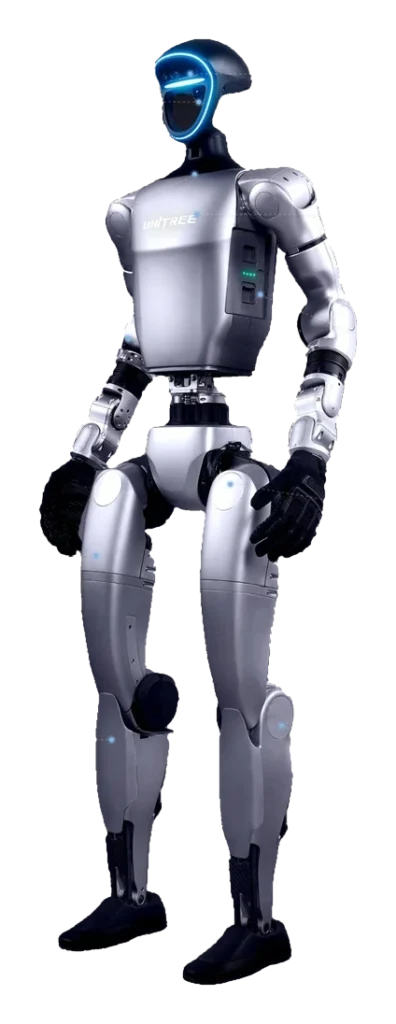
Unitree
Up to three
All humanoid robots. Every figure below is placed against the whole class, so a gap can be read against how much the class itself varies.
The conditions each robot was assessed against, side by side. Rows marked in gold are where these machines genuinely differ.
| Condition | SwitchBot Onero H1 | Unitree G1 |
|---|---|---|
| Where it operates | ||
| Home / residentialthey differ | GoodDesigned for home use; wheeled base suited to flat-surface domestic environments with standard-height appliances. | PoorG1 requires continuous programming and operator expertise unsupported in consumer settings |
| Office / retail | DependsTask set is household-focused; commercial deployments with higher throughput or structural variability are outside the stated design domain. | DependsSuitable for pre-mapped facilities with dedicated technical staff; structured inspection tasks only |
| Warehouse / factorythey differ | PoorNo published payload rating, safety certification, or industrial protocol support; not designed or marketed for industrial environments. | GoodResearch institutions and engineering labs with embedded systems expertise can deploy and customize |
| Primary tasks | ||
| Household choresthey differ | GoodCES demonstrations covered laundry, dishwashing, window cleaning, and object manipulation as core task targets. | PoorG1 lacks task generalization; household chores require adaptive decision-making and real-time replanning |
| Social / carethey differ | DependsNo documented social-interaction or companion-mode features; the H1 is task-oriented, not conversational or presence-focused. | PoorNo natural language understanding or safe human interaction guarantees; not designed for social roles |
| Specialized jobthey differ | DependsOmniSense VLA is designed for generalization, not narrow specialization; purpose-built platforms would outperform it on single specialized tasks. | GoodExcels at pre-programmed specialized tasks in controlled, pre-mapped environments |
| Supervision needs | ||
| Fully autonomous | PoorNo shipping evidence supports unattended autonomous operation; beta status means edge-case behaviors remain uncharacterized. | PoorG1 requires continuous operator supervision for all task initiation, monitoring, and error recovery |
| With oversight | GoodBeta program and CES demonstration context assume an operator is present; supervised deployment matches current capability stage. | GoodDesigned for operator oversight; firmware includes teleoperation and manual task control |
| Teleoperated | GoodSwitchBot's mid-2026 beta is structured around pilot participants providing feedback; pilot deployment is the explicit intended use at this stage. | GoodIdeal for pilot deployments with dedicated technical teams managing customization and oversight |
| Timeline | ||
| Ready today | PoorNot shipping as of June 2026; no consumer units available and general availability is expected toward year-end 2026 at earliest. | PoorNot production-ready for consumer or general commercial deployment; research platform only |
| Near-term (1–2 yrs) | DependsEnd-of-2026 or early-2027 consumer availability is plausible if beta progresses on schedule; pricing and final task capability remain unconfirmed. | DependsUnitree's roadmap indicates capability improvements; consumer viability on multi-year horizon |
| Research phase | GoodOn-device VLA architecture and 22-DoF arm system make the H1 a substantive evaluation platform for embodied AI research during the beta period. | GoodProven in research institutions; platform actively used for locomotion and manipulation studies |
A robot being poor for a condition is a fact about fit, not a fault. “Depends” means the record names a limit worth reading, not that the answer is unknown.
None of these has shipped, so they are assessed on track record, engineering plausibility and how the demonstrations match the claims.
Never averaged into it. These describe how much the maker has disclosed, not what the machine does.
| SwitchBot Onero H1 | Unitree G1 | |
|---|---|---|
| ReadinessShip-date specificity, pricing transparency, distribution and regulatory status. Published beside the number; never averaged in. | 38/100 | 90/100 |
| DisclosureHow much of the product is disclosed. Higher means fewer fundamental unknowns remain. Published beside the number; never averaged in. | 35/100 | 70/100 |
A number only means something next to the spread it sits in. Each track is the real range across every classified robot in the class, with the median marked.
Not compared, because fewer than two of these robots carry a published figure: Runtime, Charge time, Noise, Weight.
Written on each record, and the only thing here every robot on the site carries.
What each design gives up to be good at what it is good at.
The wheeled base makes flat-surface navigation tractable but rules out the stair-climbing and floor-transition capability that household generalization requires.
On-device VLA processing preserves privacy and offline function; it also means capability is bounded by what the embedded hardware can run, with no published ceiling on task complexity.
Accessible platform design versus limited autonomous decision-making. Scripted architecture lowers research barriers but restricts real-world adaptability.
Dexterous manipulation versus energy constraints. Multi-DOF gripper enables complex tasks but consumes battery reserves, reducing session duration.
Stated by the record itself. A robot being wrong for a household is a fact about fit, not a fault.
The upkeep ownership hands back to you, whatever the autonomy level says.
Classifications rest on different depths of evidence. A pre-release assessment and a verified one are not the same kind of claim.
| Robot | Evidence status | Sources reviewed | Last assessed |
|---|---|---|---|
| SwitchBot Onero H1 | Pre-Release | 1 | Aug 2026 |
| Unitree G1 | Not Consumer-Ready | 13 | Sep 2026 |
Evidence status counts the sources behind a classification, not their kind. A high count can be maker documentation and price coverage, so read it as how much was reviewed rather than as independent testing. How we weigh evidence.
 The full recordSwitchBot Onero H1Specifications, evidence, the Fit Check in full, and every tracked change.
 The full recordUnitree G1Specifications, evidence, the Fit Check in full, and every tracked change.
Robovations classifies robots; it does not rank them. Nothing on this page is a recommendation, and no manufacturer influences a classification or its placement here.
Comparing across classes is allowed — the page will switch to per-class positioning and tell you it has.