
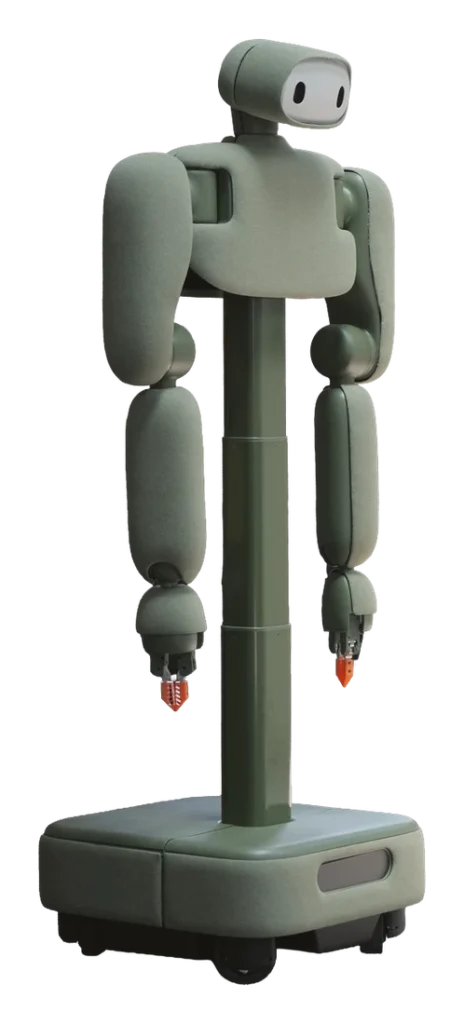
Weave Robotics
Weave Isaac 1
- Autonomy
- IIAssisted
- Pre-release
- 45/100Concept Stage
- Readiness
- Not assessed
- Price
- $7,999list
Weave Robotics

Sunday Robotics
Up to three
All multi-task robots. Every figure below is placed against the whole class, so a gap can be read against how much the class itself varies.
The conditions each robot was assessed against, side by side. Rows marked in gold are where these machines genuinely differ.
| Condition | Weave Isaac 1 | Sunday Robotics Memo |
|---|---|---|
| Primary use case | ||
| Home / residential | GoodDesigned explicitly for ordinary home environments: laundry, beds, clutter, hampers. | GoodHumanoid form factor and dual-arm design support household navigation and object manipulation. |
| Professional settingthey differ | PoorNo documented commercial or professional deployment mode; hardware and pricing target residential use. | DependsLearning-based architecture assumes dedicated training staff; industrial deployments would require on-site roboticists. |
| Mixed contexts | DependsHome-only task set documented; no evidence of professional or shared-space capability. | DependsSkill generalization across environments is unproven; variable layouts may require repeated retraining. |
| Task variety | ||
| One or two tasks | DependsTask set covers laundry and tidying specifically; buyers needing only one task may find the price hard to justify. | DependsPlatform is built for learning multiple behaviors, not single-task optimization; using it for one routine is overkill. |
| Several tasks | GoodLaundry Flow, bed-making, clutter tidying, and item placement cover a meaningful range of home manipulation tasks. | GoodImitation-learning architecture designed to acquire diverse household behaviors through demonstration. |
| General-purposethey differ | PoorOpen-ended task execution beyond the documented chore set is not supported; manipulation is domain-specific. | GoodThe platform's strength is task flexibility without pre-programmed limits; novel behaviors can be taught as needed. |
| Environment | ||
| Controlled / familiar | GoodPerforms best in tidy, obstacle-clear homes with navigable floor paths and standard doorway widths. | GoodWheeled platform and learning pipeline work best in stable, known environments where training can be consistent. |
| Shared with people | DependsTeleoperator fallback introduces remote video access; shared living spaces raise privacy considerations for all occupants. | DependsUnproven how learned behaviors handle dynamic household variables (moving furniture, pets, children). |
| Unstructured spaces | PoorCluttered, unpredictable, or frequently rearranged environments exceed documented navigation reliability at this stage. | PoorPre-release platform with no generalization evidence; outdoor or unstructured environments not documented. |
| Oversight model | ||
| Autonomous operation | PoorTeleoperator fallback is part of the documented operation model; fully autonomous, unattended operation is not confirmed. | PoorLearning-based execution requires human trainer oversight and task-definition maintenance; not set-and-forget. |
| Light supervision | GoodDesigned for supervised home use with remote human assistance available when the robot cannot complete a task. | GoodActive human involvement in learning and task validation matches the platform's current design. |
| Active operator | GoodEarly-adopter pre-order structure suits buyers comfortable with pilot-phase hardware and iterative capability improvements. | GoodPilot deployments with dedicated staff are the target use case for this unshipped platform. |
A robot being poor for a condition is a fact about fit, not a fault. “Depends” means the record names a limit worth reading, not that the answer is unknown.
None of these has shipped, so they are assessed on track record, engineering plausibility and how the demonstrations match the claims.
Excluded as unevidenced, so it is left out of the number: Sunday Robotics Memo
Never averaged into it. These describe how much the maker has disclosed, not what the machine does.
| Weave Isaac 1 | Sunday Robotics Memo | |
|---|---|---|
| ReadinessShip-date specificity, pricing transparency, distribution and regulatory status. Published beside the number; never averaged in. | 84/100 | 70/100 |
| DisclosureHow much of the product is disclosed. Higher means fewer fundamental unknowns remain. Published beside the number; never averaged in. | 38/100 | 40/100 |
A number only means something next to the spread it sits in. Each track is the real range across every classified robot in the class, with the median marked.
Not compared, because fewer than two of these robots carry a published figure: Price, Noise, Weight.
Written on each record, and the only thing here every robot on the site carries.
What each design gives up to be good at what it is good at.
Teleoperation is not a fallback feature. It is the current autonomy ceiling. Level II classification holds until Weave documents end-to-end task completion without remote human intervention.
Successor to a stationary robot (Isaac 0); the wheeled base and manipulation arm represent a significant mechanical leap with no shipping track record to validate durability or failure rates.
Subscription pricing ($449/month) means the total cost of ownership over two years exceeds the one-time purchase price. And feature availability may depend on continued subscription status.
Learning flexibility comes at the cost of constant human involvement. Every new task requires demonstration, iteration, and domain expertise; fully autonomous execution is the goal, not the starting state.
The skills are pre-trained, not taught by the buyer: dishwashing, espresso and folding come out of the ACT-1 model, trained on roughly 10 million episodes captured in more than 500 real homes. That buys a machine with a repertoire on day one, and it costs the household any say in what the repertoire contains, because the data pipeline is Sunday’s to run.
Stated by the record itself. A robot being wrong for a household is a fact about fit, not a fault.
The upkeep ownership hands back to you, whatever the autonomy level says.
Classifications rest on different depths of evidence. A pre-release assessment and a verified one are not the same kind of claim.
| Robot | Evidence status | Sources reviewed | Last assessed |
|---|---|---|---|
| Weave Isaac 1 | Pre-Release | 2 | Sep 2026 |
| Sunday Robotics Memo | Pre-Release | 3 | Aug 2026 |
Evidence status counts the sources behind a classification, not their kind. A high count can be maker documentation and price coverage, so read it as how much was reviewed rather than as independent testing. How we weigh evidence.
 The full recordWeave Isaac 1Specifications, evidence, the Fit Check in full, and every tracked change.
 The full recordSunday Robotics MemoSpecifications, evidence, the Fit Check in full, and every tracked change.
 Written comparisonWhich home robots still rely on a human teleoperator?We have examined this pairing in full, with a stated finding.
Robovations classifies robots; it does not rank them. Nothing on this page is a recommendation, and no manufacturer influences a classification or its placement here.
Comparing across classes is allowed — the page will switch to per-class positioning and tell you it has.