
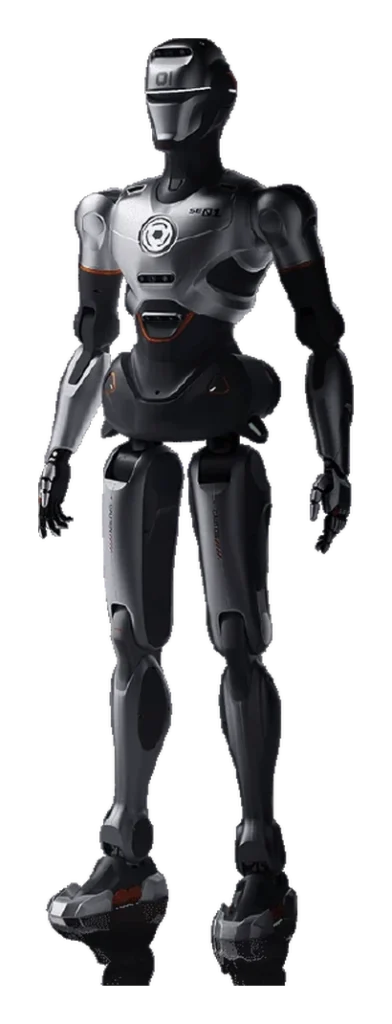
EngineAI
EngineAI PM01
- Autonomy
- IIAssisted
- Pre-release
- 49/100Concept Stage
- Readiness
- Not assessed
- Price
- Not tracked
EngineAI
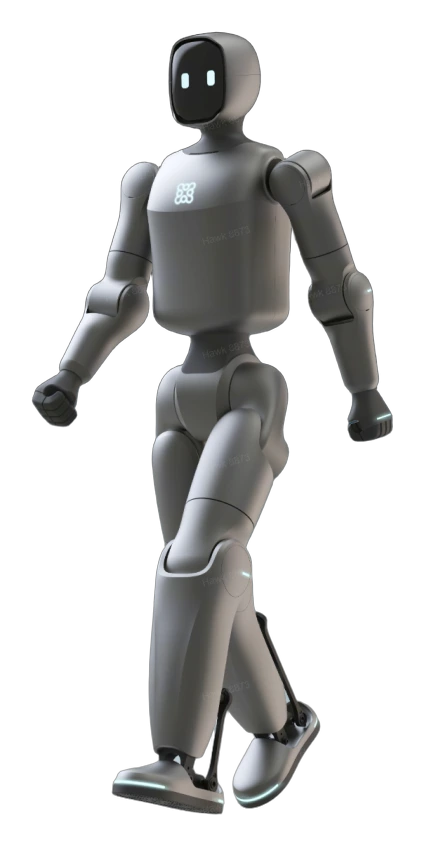
Zeroth
Up to three
All humanoid robots. Every figure below is placed against the whole class, so a gap can be read against how much the class itself varies.
The conditions each robot was assessed against, side by side. Rows marked in gold are where these machines genuinely differ.
| Condition | EngineAI PM01 | Zeroth Bridge |
|---|---|---|
| Where it operates | ||
| Home / residentialthey differ | PoorNo consumer support or home-use documentation; developer platform only. | DependsSmall enough for a home at 88 cm and 13 kg, but it ships with motion routines, not household tasks. |
| Office / retailthey differ | PoorNot positioned for commercial deployment without significant integration work. | DependsZeroth sells it to universities, research teams and developers; no commercial deployment is documented. |
| Warehouse / factorythey differ | DependsPossible in research or pilot deployments with technical staff; no production SLA. | PoorA 2 kg gripper payload and 10 N·m joints are sized for development benches, not industrial work. |
| Primary tasks | ||
| Household chores | PoorNo published task capability or manipulation scope beyond research prototyping. | PoorBuilt-in skills are walking, squatting, dancing and backflips; no chore routine appears in any source reviewed. |
| Social / carethey differ | PoorNo documented interaction or communication features. | DependsA microphone array and touch sensing are listed, but no conversational software is described for Bridge. |
| Specialized job | GoodMobile manipulation research and algorithm development are core. | GoodAn open SDK, motion-control APIs and teleoperation let developers build their own specialized skills. |
| Supervision needs | ||
| Fully autonomous | PoorDeveloper platform requires active monitoring and iterative debugging. | PoorControl is replayed motion or live teleoperation; no unattended task operation is documented. |
| With oversightthey differ | GoodLab or research environment with technical staff is the intended context. | DependsFall recovery and emergency-stop behavior are undocumented, so an operator should stay close during dynamic routines. |
| Teleoperated | GoodEarly-access or pilot deployments with engineering support suit the platform. | GoodTele_Bridge gives a developer real-time whole-body control with VR support, the mode Zeroth designed it for. |
| Timeline | ||
| Ready today | PoorPre-release; not consumer-ready or production-hardened. | PoorFirst-batch units are a pre-order with no delivery date on Zeroth's store. |
| Near-term (1–2 yrs) | DependsPossible broader release after research validation; no timeline published. | DependsOrders are open in the US and China, but neither channel states when units deliver. |
| Research phase | GoodCore design intent for developer and research-market deployment. | GoodPitched at research teams, with SDK beta and simulation access starting 14 Sep 2026. |
A robot being poor for a condition is a fact about fit, not a fault. “Depends” means the record names a limit worth reading, not that the answer is unknown.
None of these has shipped, so they are assessed on track record, engineering plausibility and how the demonstrations match the claims.
Never averaged into it. These describe how much the maker has disclosed, not what the machine does.
| EngineAI PM01 | Zeroth Bridge | |
|---|---|---|
| ReadinessShip-date specificity, pricing transparency, distribution and regulatory status. Published beside the number; never averaged in. | 40/100 | 60/100 |
| DisclosureHow much of the product is disclosed. Higher means fewer fundamental unknowns remain. Published beside the number; never averaged in. | 55/100 | 45/100 |
A number only means something next to the spread it sits in. Each track is the real range across every classified robot in the class, with the median marked.
Not compared, because fewer than two of these robots carry a published figure: Price, Runtime, Charge time, Noise.
Written on each record, and the only thing here every robot on the site carries.
What each design gives up to be good at what it is good at.
Compact form reduces footprint and power demand; carrying capacity and dexterity are constrained compared to full-size research platforms.
Developer pricing attracts research teams; minimal or no consumer support infrastructure means buyer assumes integration and troubleshooting burden.
$3,999 buys a biped with a published joint map and no published runtime.
Because control is replayed motion or live teleoperation, every new behavior is something a developer has to build.
Two weights on one page: about 10 kg in the header, about 13 kg in the spec table.
Stated by the record itself. A robot being wrong for a household is a fact about fit, not a fault.
The upkeep ownership hands back to you, whatever the autonomy level says.
Classifications rest on different depths of evidence. A pre-release assessment and a verified one are not the same kind of claim.
| Robot | Evidence status | Sources reviewed | Last assessed |
|---|---|---|---|
| EngineAI PM01 | Not Consumer-Ready | 4 | Sep 2026 |
| Zeroth Bridge | Pre-Release | 6 | Sep 2026 |
Evidence status counts the sources behind a classification, not their kind. A high count can be maker documentation and price coverage, so read it as how much was reviewed rather than as independent testing. How we weigh evidence.
 The full recordEngineAI PM01Specifications, evidence, the Fit Check in full, and every tracked change.
 The full recordZeroth BridgeSpecifications, evidence, the Fit Check in full, and every tracked change.
Robovations classifies robots; it does not rank them. Nothing on this page is a recommendation, and no manufacturer influences a classification or its placement here.
Comparing across classes is allowed — the page will switch to per-class positioning and tell you it has.