
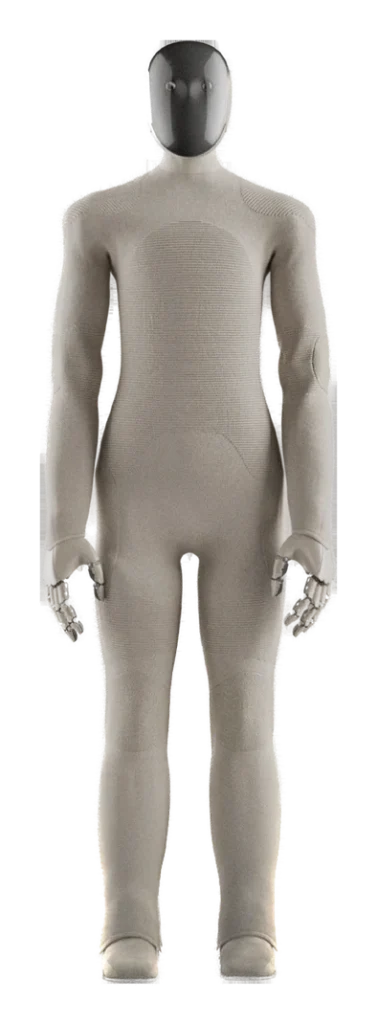
1X Technologies
1X NEO
- Autonomy
- IIAssisted
- Pre-release
- 63/100Plausible
- Readiness
- Known Issues
- Price
- $20,000list
1X Technologies
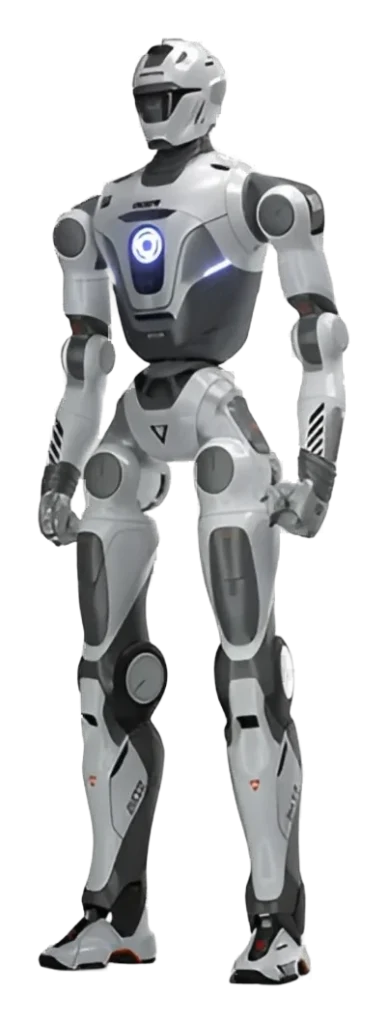
EngineAI
Up to three
All humanoid robots. Every figure below is placed against the whole class, so a gap can be read against how much the class itself varies.
The conditions each robot was assessed against, side by side. Rows marked in gold are where these machines genuinely differ.
| Condition | 1X NEO | EngineAI T800 |
|---|---|---|
| Where it operates | ||
| Home / residentialthey differ | GoodDesigned specifically for household environments; soft-body safety profile matches residential spaces well. | PoorNo home-use documentation exists; 75 kg platform and $25K entry price preclude consumer home deployment. |
| Office / retail | DependsCommercial deployments underway with subscription support, but scale and reliability in diverse facilities still limited. | DependsMax Edition targets 24/7 commercial deployment, but no published SLA or support structure is available to buyers outside China. |
| Warehouse / factorythey differ | PoorSoft actuators and residential design do not meet industrial durability or force requirements. | GoodHigh-torque actuators and robust frame suit structured industrial pilot environments with on-site engineering staff. |
| Primary tasks | ||
| Household choresthey differ | GoodLight cleaning, object retrieval, and maintenance routines are primary demonstrated use cases. | PoorNo published household task capability; manipulation software for domestic chores is not documented. |
| Social / carethey differ | DependsOperator control enables interaction but requires real-time human piloting; autonomous presence is limited. | PoorNo interaction or communication features documented; positioned for physical tasks, not social engagement. |
| Specialized jobthey differ | PoorSoft actuators lack force and precision for specialized tasks like assembly, repair, or delicate handling. | GoodHigh-DOF body and optional dexterous hands suit specialized manipulation research and custom task development. |
| Supervision needs | ||
| Fully autonomous | PoorContinuous operator oversight required; not suitable for unattended autonomous operation. | PoorAutonomous task completion without supervision is not documented; platform requires active monitoring in current form. |
| With oversightthey differ | GoodOperator monitoring and intervention model aligns with supervision-level expectations. | DependsSupervised operation is feasible for research or pilot contexts, but software integration burden is high. |
| Teleoperated | GoodExpert-pilot subscription tier explicitly designed for operator-controlled deployment and workflow integration. | GoodDesigned for pilot deployments with engineering support; first-batch buyers are expected to have integration capacity. |
| Timeline | ||
| Ready todaythey differ | DependsAvailable now through commercial subscription but not retail-ready; early deployments show promise but limited scale. | PoorConsumer-ready or production-ready deployment is not supported; platform is in early commercial rollout in China only. |
| Near-term (1–2 yrs)they differ | GoodEngineering roadmap signals incremental autonomy improvements; pathway to higher autonomy levels documented. | DependsInternational availability and task-level software maturity could unlock broader deployment within 12-24 months if software roadmap delivers. |
| Research phase | GoodPre-release platform suitable for research partnerships and feasibility pilots. | GoodCore positioning targets research institutions; ROS2 and NVIDIA compute stack support algorithm development workflows. |
A robot being poor for a condition is a fact about fit, not a fault. “Depends” means the record names a limit worth reading, not that the answer is unknown.
None of these has shipped, so they are assessed on track record, engineering plausibility and how the demonstrations match the claims.
Never averaged into it. These describe how much the maker has disclosed, not what the machine does.
| 1X NEO | EngineAI T800 | |
|---|---|---|
| ReadinessShip-date specificity, pricing transparency, distribution and regulatory status. Published beside the number; never averaged in. | 90/100 | 70/100 |
| DisclosureHow much of the product is disclosed. Higher means fewer fundamental unknowns remain. Published beside the number; never averaged in. | 55/100 | 40/100 |
A number only means something next to the spread it sits in. Each track is the real range across every classified robot in the class, with the median marked.
Not compared, because fewer than two of these robots carry a published figure: Noise.
Written on each record, and the only thing here every robot on the site carries.
What each design gives up to be good at what it is good at.
Tendon-driven compliance maximizes safety in shared spaces but leaves precision and contact-sensitive work unproven; with a published 154 lb lift and 18 lb per-arm payload, raw force is not what the design gives up.
Operator partnership ensures task flexibility and professional support but requires continuous human labor cost.
A $499 per month plan makes a home humanoid reachable without a $20,000 purchase, but keeps the robot on an ongoing subscription rather than owned outright.
450 Nm peak torque and 14,000 W instantaneous joint power are genuinely high hardware specifications; the autonomy software layer to deploy that hardware on real tasks is undocumented.
Solid-state battery and modular hot-swap design solve a real operational problem. Four-edition tiering creates meaningful choice; Basic Edition lacks dexterous hands, limiting manipulation tasks entirely.
Stated by the record itself. A robot being wrong for a household is a fact about fit, not a fault.
The upkeep ownership hands back to you, whatever the autonomy level says.
Classifications rest on different depths of evidence. A pre-release assessment and a verified one are not the same kind of claim.
| Robot | Evidence status | Sources reviewed | Last assessed |
|---|---|---|---|
| 1X NEO | Pre-Release | 12 | Sep 2026 |
| EngineAI T800 | Not Consumer-Ready | 8 | Sep 2026 |
Evidence status counts the sources behind a classification, not their kind. A high count can be maker documentation and price coverage, so read it as how much was reviewed rather than as independent testing. How we weigh evidence.
 The full record1X NEOSpecifications, evidence, the Fit Check in full, and every tracked change.
 The full recordEngineAI T800Specifications, evidence, the Fit Check in full, and every tracked change.
Robovations classifies robots; it does not rank them. Nothing on this page is a recommendation, and no manufacturer influences a classification or its placement here.
Comparing across classes is allowed — the page will switch to per-class positioning and tell you it has.